

Cyberbotics Ships Webots R2025a With Marine Robots and Drops ROS 1
Cyberbotics ships R2025a of its open-source 3D robot simulator with a new marine robot, refreshed ROS 2 packages, and a formal ROS 1 sunset.
 PRO
- Cyberbotics released Webots R2025a, the latest stable of its Apache 2 open-source 3D robot simulator.
- New Clearpath Heron unmanned surface vehicle model adds marine and swarm simulation to the asset library.
- ROS 2 bridge gains dedicated
webots_ros2_husarionandwebots_ros2_crazyfliepackages. - ROS 1 (
webots_ros) is deprecated in line with Noetic end-of-life; Iron support dropped in favor of Humble and Jazzy. - Binaries ship for Windows, Ubuntu 22.04/24.04, macOS, Snap, and Docker from cyberbotics.com.
- Controllers still work in C, C++, Python, Java, MATLAB, and ROS with an unchanged core API.
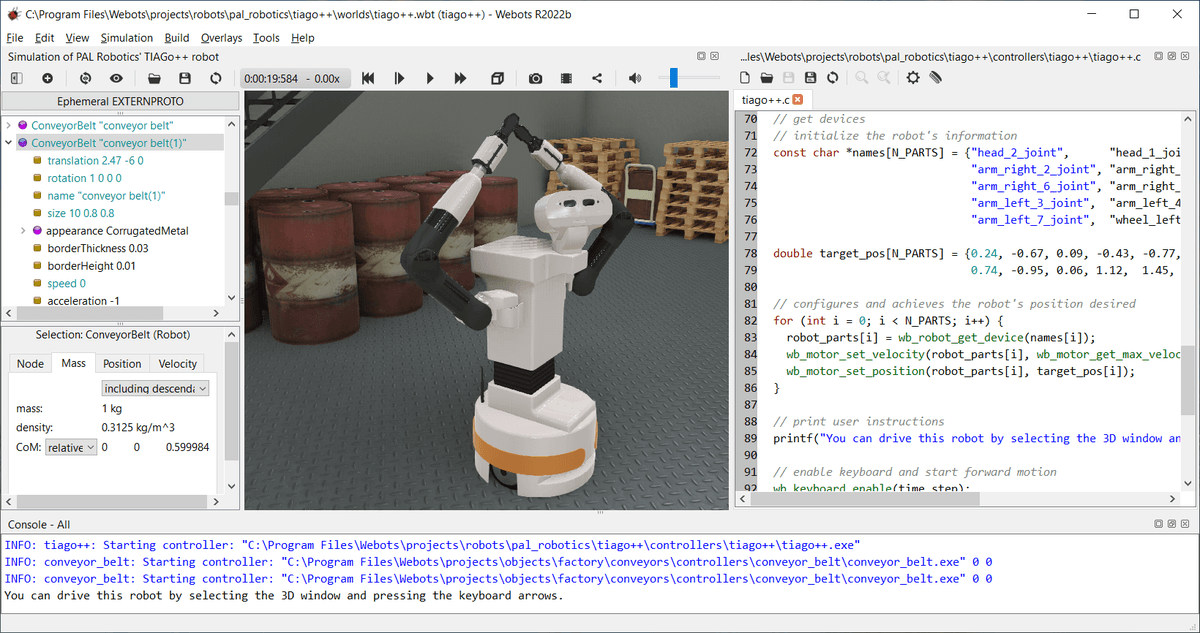
Cyberbotics has cut a new stable release of its open-source robot simulator, Webots R2025a. The update lands a new marine robot model, tightens the ROS 2 bridge, deprecates ROS 1 support, and rolls in the usual pile of physics and rendering fixes. For anyone building control policies, doing sim-to-real, or teaching robotics, this is the version you now want on disk.
Webots is a desktop simulator that started at EPFL in 1996 and has been maintained by Cyberbotics since 1998. Since December 2018, it is released under the free and open-source Apache 2 license. The R2025a tag was published on GitHub with binaries for Windows, Ubuntu 22.04/24.04, macOS, a Snap package, and a Docker image.
What actually changed
The release notes summarize R2025a as some new robot model, new demos, improved ROS 2 support, and many other improvements. It is recommended to proceed with this update. Under that vague headline, a few things matter for people actually running simulations:
- New robot: Clearpath Heron USV. The Clearpath Heron USV model, introduced in Webots R2025a, supports simulation of marine operations like swarm coordination and ocean patrolling, with thruster dynamics and sensor fusion for COLREG-compliant path planning. That fills a real gap: Webots already covered ground robots, arms, drones, and underwater vehicles, but surface craft were thin.
This story is for Pro members
You've reached the end of the free preview. Upgrade to AlphaSignal Pro to read the full article - and everything else behind the paywall.
Comments
