

Berkeley's mjlab Ditches Omniverse to Make Robot Training Lightweight
A new open-source robot learning framework fuses Isaac Lab's manager-based API with MuJoCo Warp's GPU physics, installable in one command.
 PRO
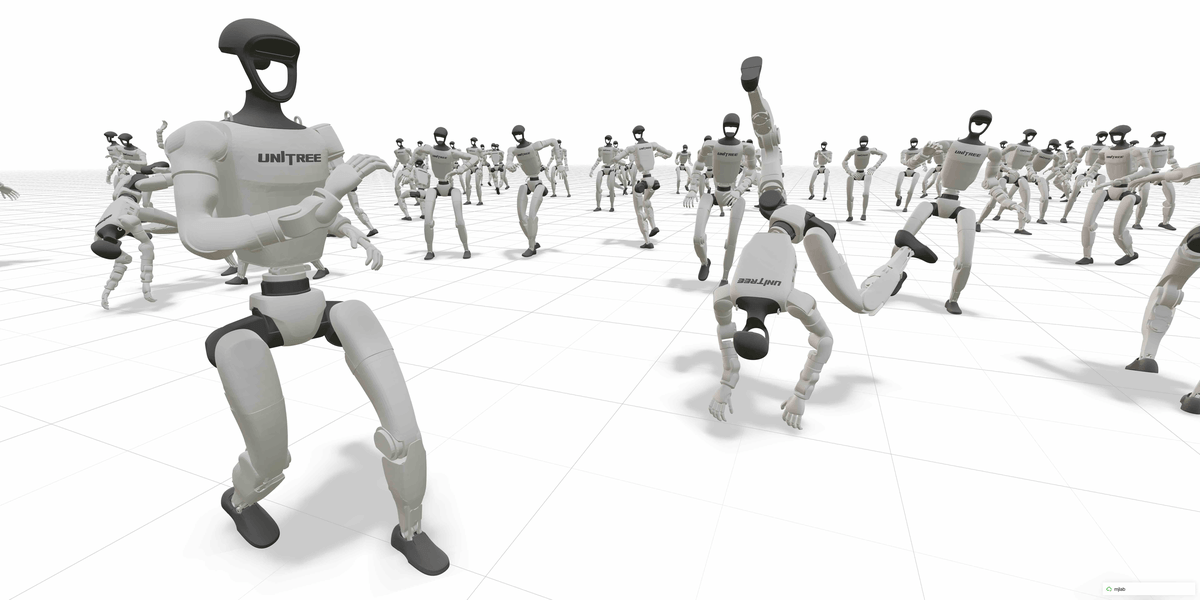
- mjlab pairs Isaac Lab's manager-based API with MuJoCo Warp GPU physics in one lightweight package (repo)
- Installs and runs with a single
uvx --from mjlab --refresh democommand, no Omniverse required - Ships reference tasks for velocity tracking, motion imitation, and manipulation on Unitree G1
- Exposes native MuJoCo
MjModel/MjDataand works directly with MJCF and Menagerie assets - Multi-GPU training via
--gpu-ids, RSL-RL integration, and W&B checkpoint fetching built in - Paper by Kevin Zakka, Pieter Abbeel et al. available on arXiv, Apache-2.0 licensed
Robot learning tooling has been stuck in an awkward split. Isaac Lab gives you a clean, composable API but drags in NVIDIA Omniverse and multi-gigabyte downloads, while MuJoCo Playground is fast to hack on but encourages copy-pasted monolithic environments. mjlab, a new framework from a Berkeley-affiliated team, grafts Isaac Lab's API onto MuJoCo Warp, the GPU-accelerated version of MuJoCo.
According to the team's paper, mjlab installs with a single command, ships minimal dependencies, and hands users direct access to native MuJoCo data structures. The repo has already crossed 2,000 stars.
The gap it's plugging
The authors are direct about their positioning. Isaac Lab provides a comprehensive manager-based API for composing RL environments but requires the Omniverse runtime, which adds installation complexity and startup latency. MuJoCo Playground takes the opposite approach with minimal abstractions and monolithic environment definitions that are easy to hack and quick to prototype, though code duplication across robots and tasks makes multi-task codebases difficult to maintain.
mjlab sits in between. Users compose self-contained building blocks for observations, rewards, events, and commands, paired with MuJoCo Warp for GPU-accelerated physics. The result: fast startup, a small dependency footprint, direct access to native MuJoCo model and data structures, and a PyTorch-native interface for policy training.
This story is for Pro members
You've reached the end of the free preview. Upgrade to AlphaSignal Pro to read the full article - and everything else behind the paywall.
Comments
